


● Four-wheel-steer robot chassis
LUCHS A
BUILT FOR ROBOTS.
STEERS EVERY WHEEL.
Chassis by RJ Tech Limited / Autonomy by TerraAgent Robotics (TAR)
A compact, open mobile base for robots that need to get around.
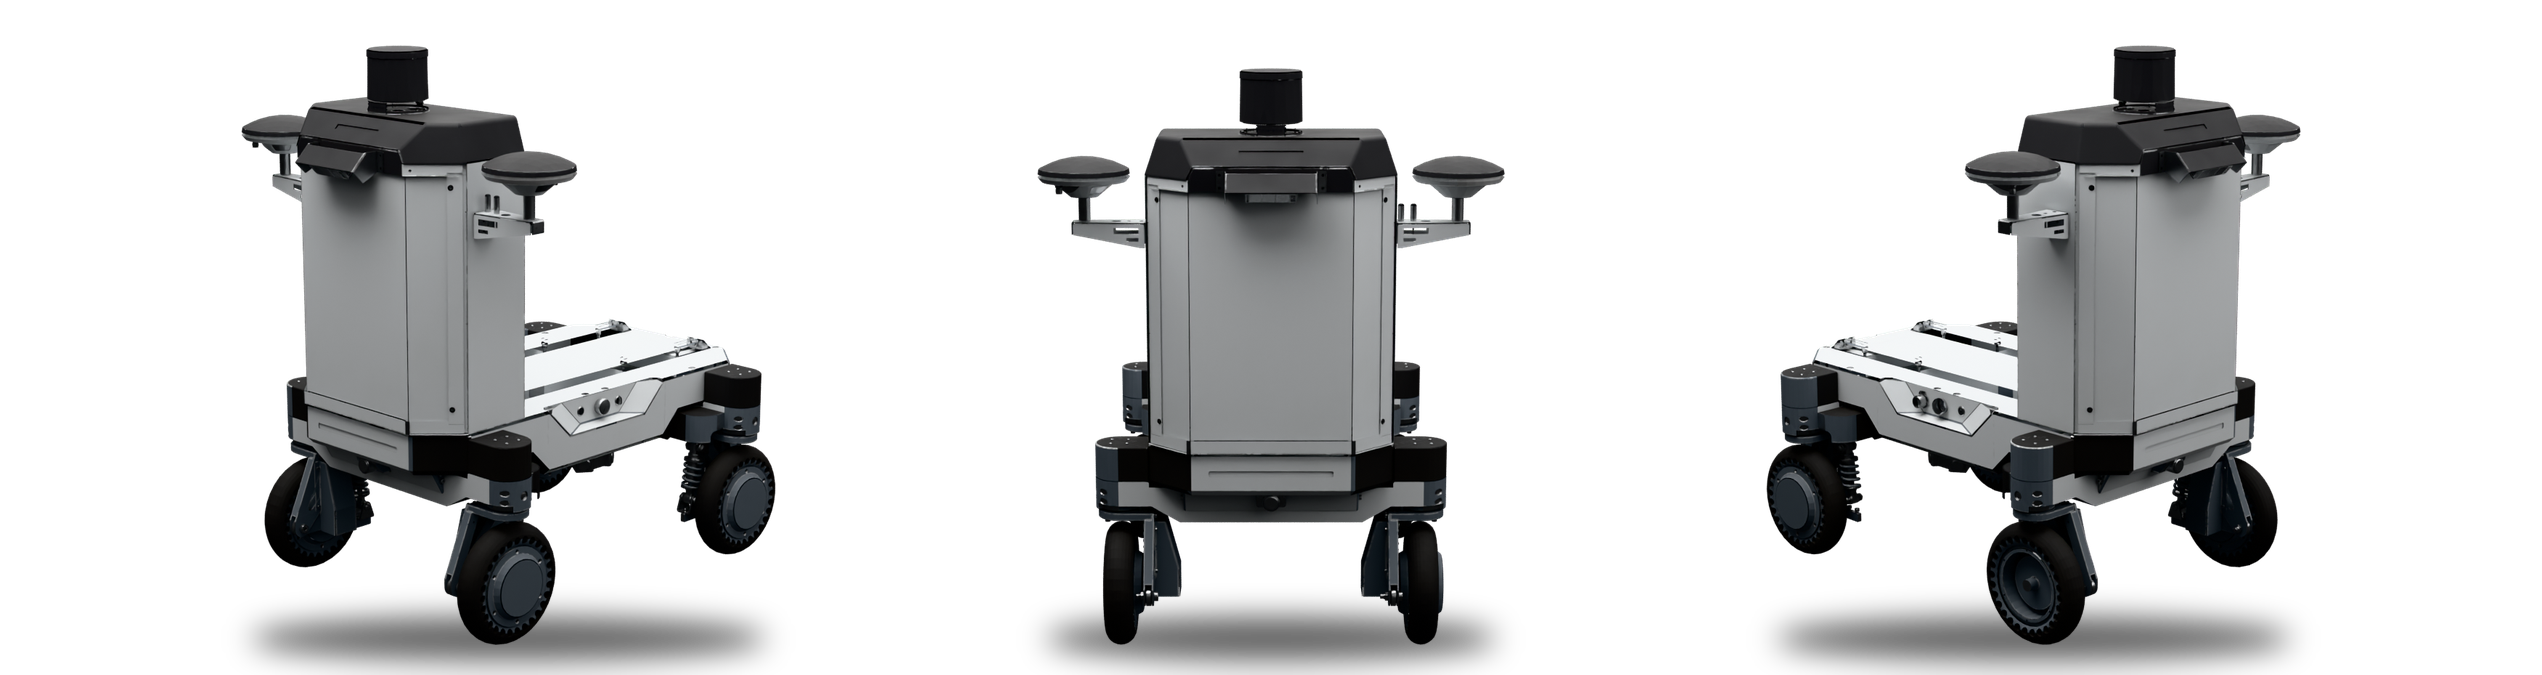
Luchs A gives your robot a reliable pair of legs. It carries up to 100 kg, steers all four wheels, and talks to your computer over standard industrial interfaces. Mount your sensors and payload on the top rails, plug into the expansion bay, and start building the application instead of the drivetrain.
Four drive configurations, one platform. Skid-steer, front Ackermann, dual Ackermann or full four-wheel steering. The main body is shared; only the drive module changes. The line-up above shows all four builds.
Open by design. CAN, RS-485 and RS-232 control, a published protocol, and ROS 2 software with an SDK, robot model and simulator in the box.
Power for your payload. 48 V / 10 A and 12 V / 8 A outputs, each with over-current, short-circuit and over-temperature protection.
Safety you don't have to add later. Dual emergency stops, ultrasonic collision stop, power-on self-test and a monitored battery.
Two ways to buy. Take Luchs A as an open chassis for your own robot software, or with the TAR navigation kit and autonomy already on board. One platform, two starting points: you choose how much we deliver.
Advanced Features
Engineered for autonomy, indoors and out
Intelligent VCU
Speed, yaw-rate and steering commands over CAN 1 Mbit/s or RS-485 / RS-232, with odometry-grade feedback. ROS 2 and ROS 1 drivers and a C++ SDK.
Independent Suspension
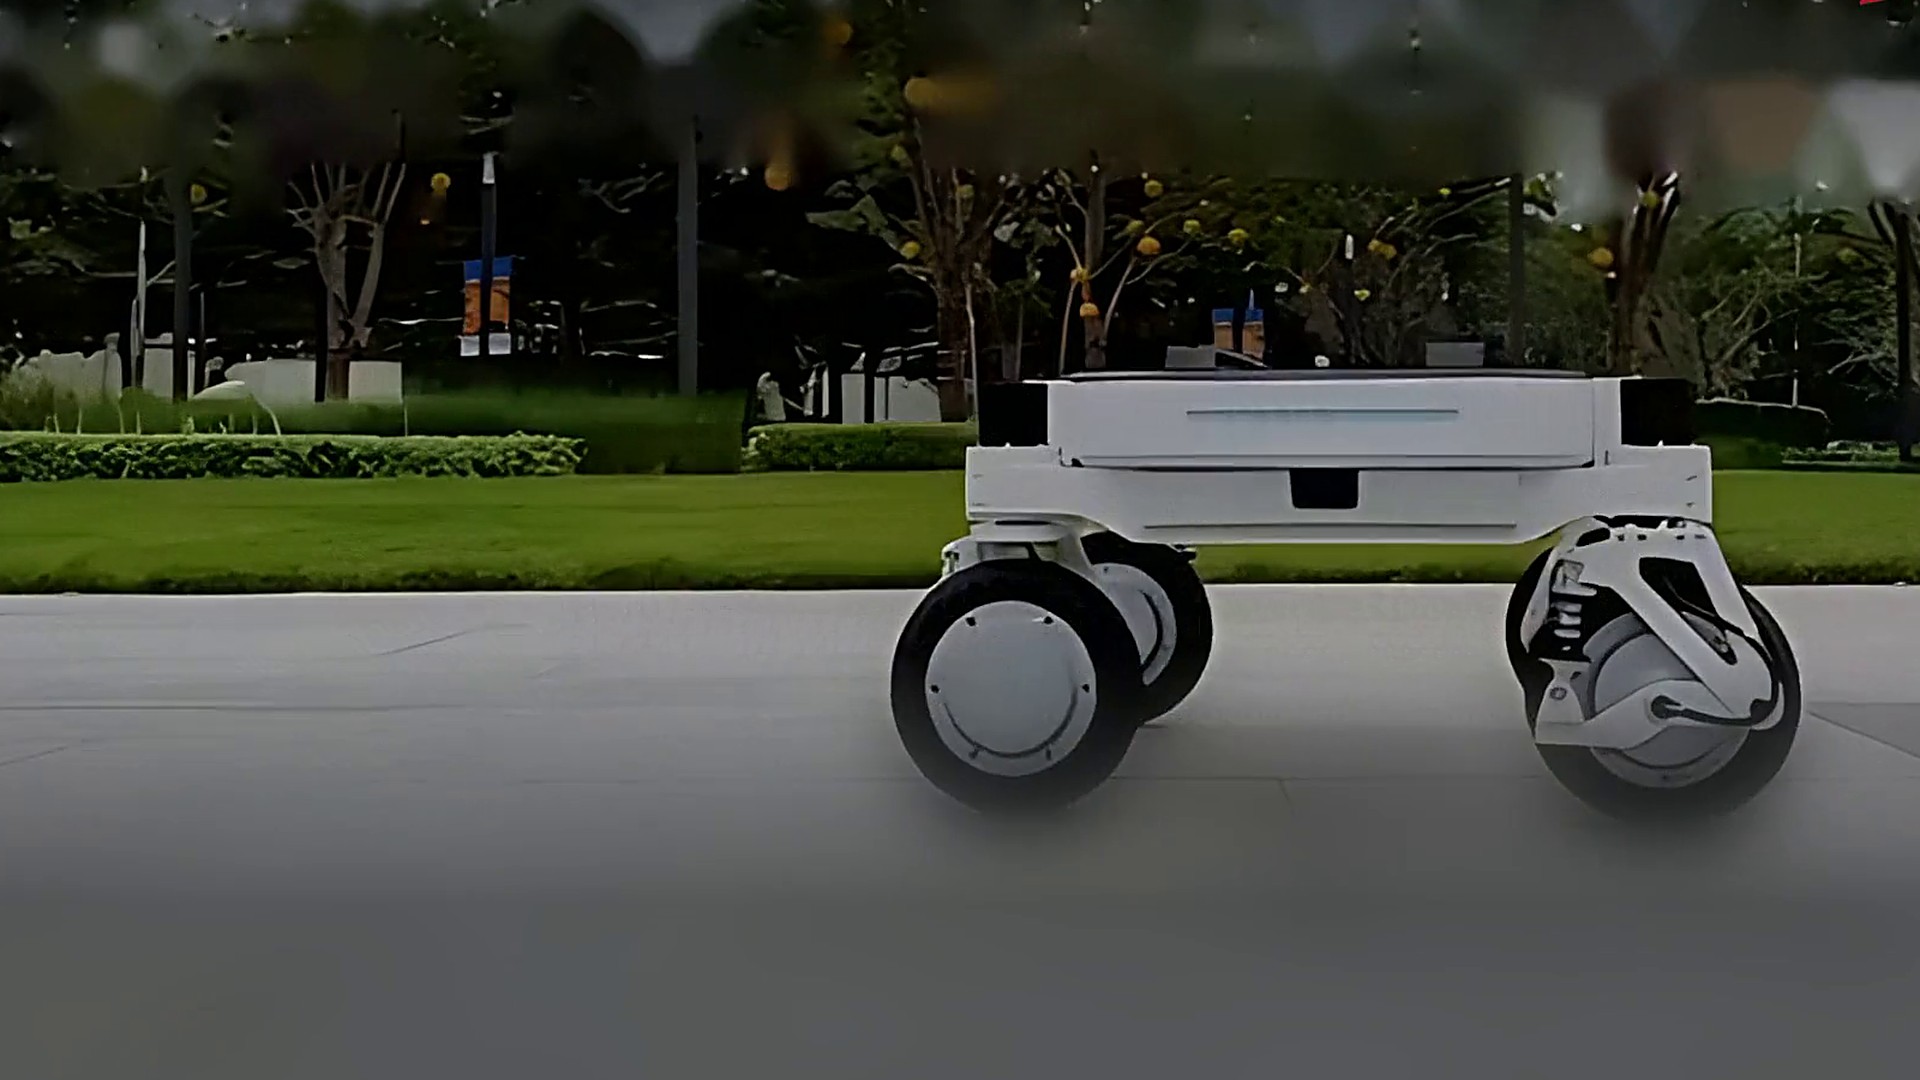
Double wishbone front and rear on the A-DF, A-FA and A-DA builds; independent swing arms on the four-wheel-steer A-4WS.
Distributed Electric Drive
Four 250 W servo hub motors, one per wheel. On the A-4WS, four 140 W steering servos turn every wheel.
Strong Lightweight Structure
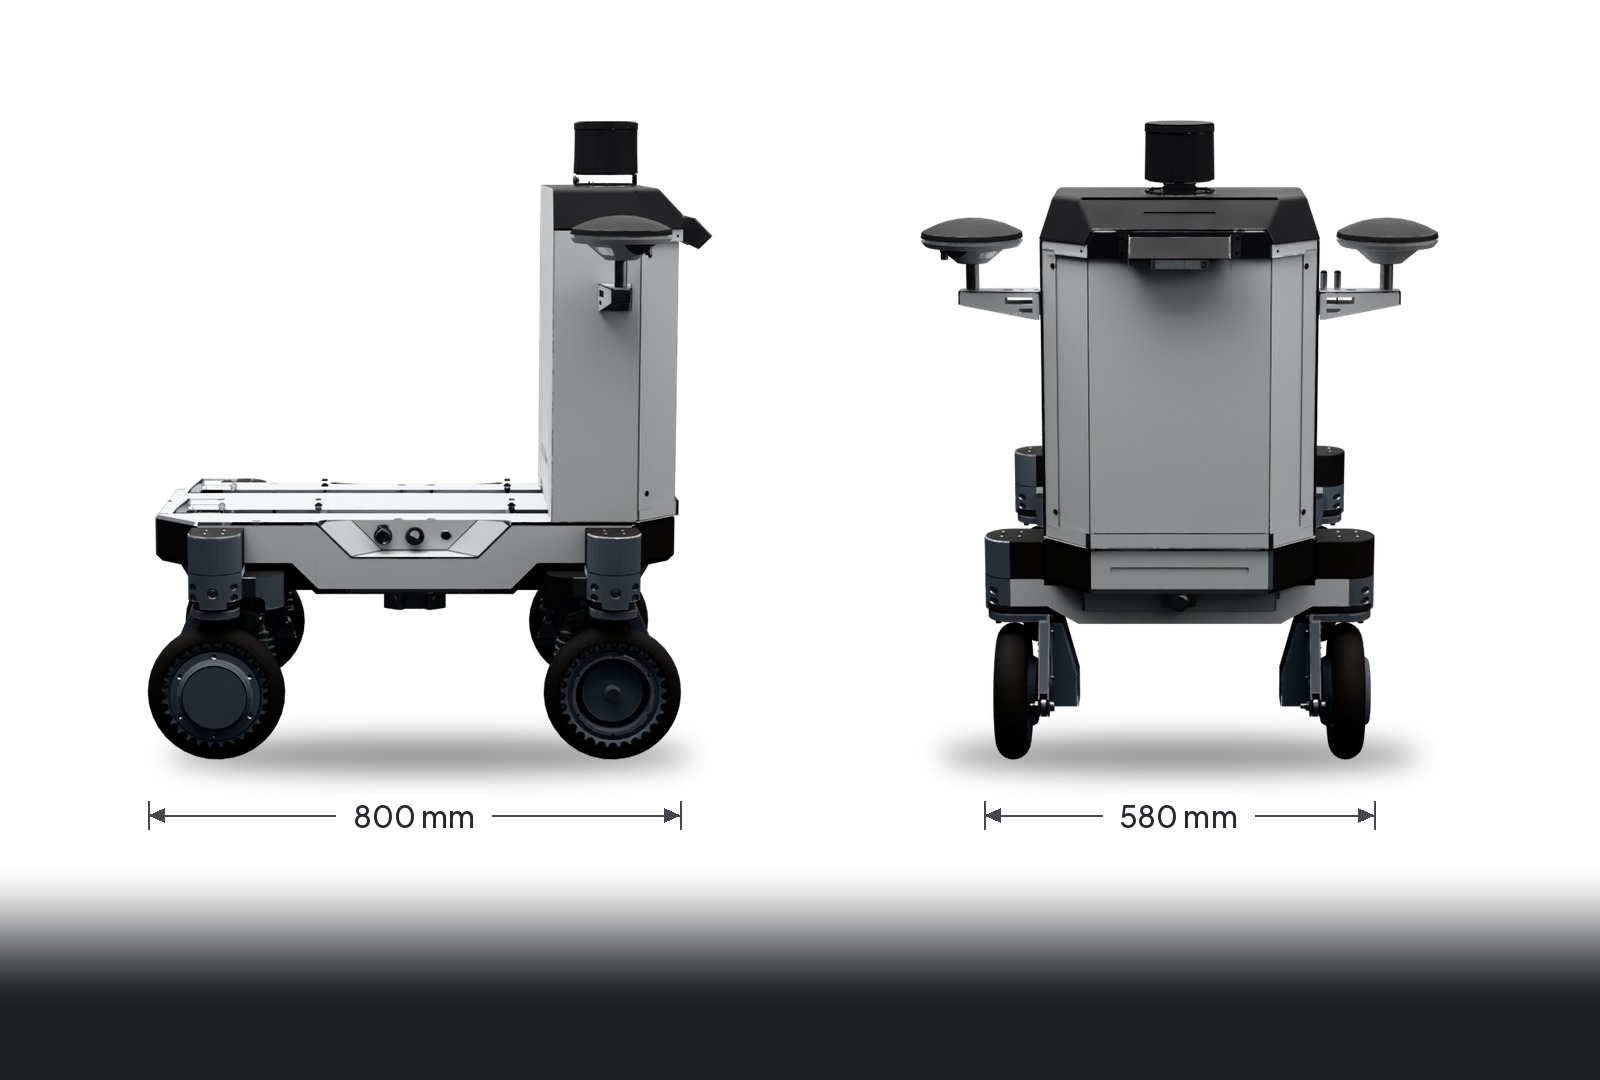
Carbon steel and aluminium alloy frame. 65 kg chassis on an 800 × 580 mm footprint, carrying up to 100 kg.
Energy Management System
48 V 30 Ah LiFePO4 battery with BMS: up to 12 h unloaded on one charge. Drive is disabled while the charger is connected.
Payload Rails and Power
Two 2040 aluminium rails, 700 mm long at 200 mm centres, plus 48 V / 10 A and 12 V / 8 A outputs for your sensors and computer.
Technical Specifications
Precision-engineered for demanding applications — Choose your variant
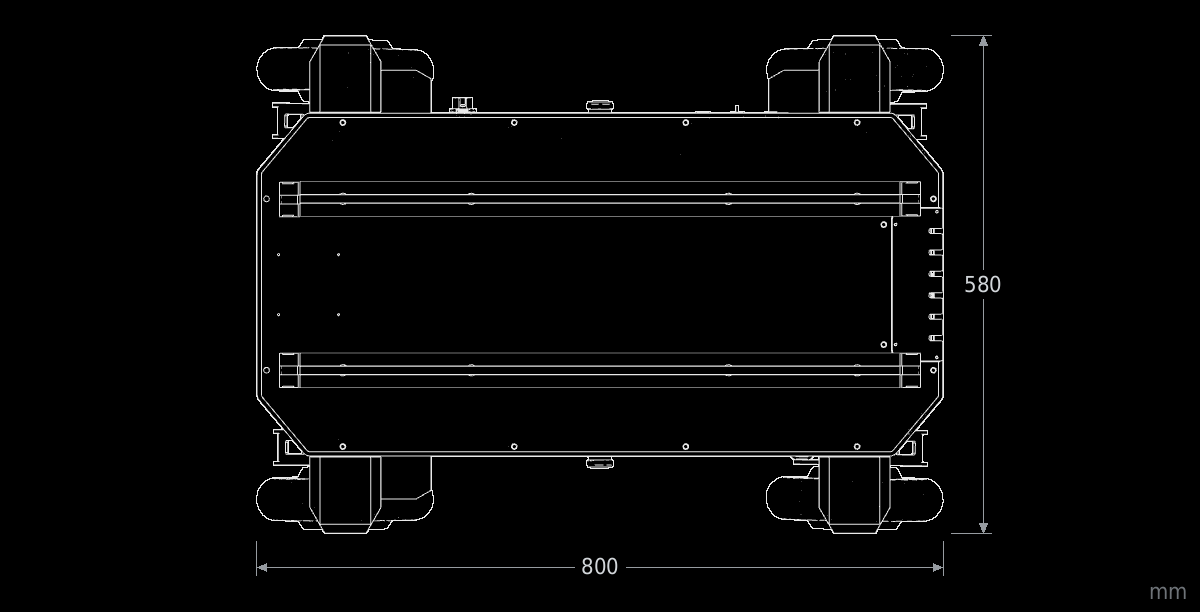
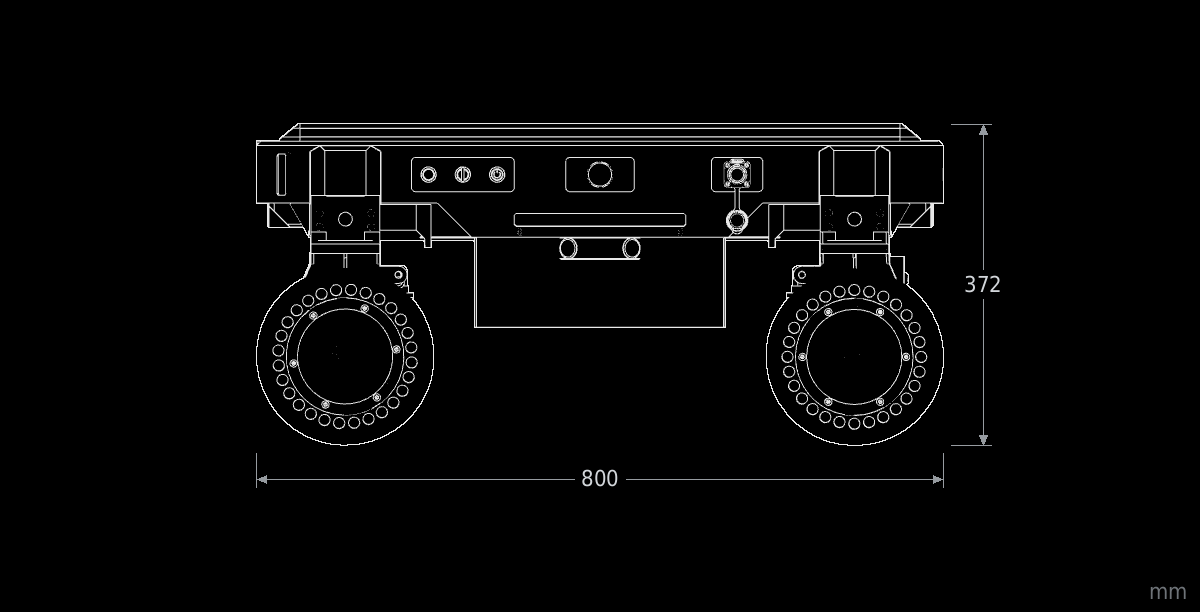
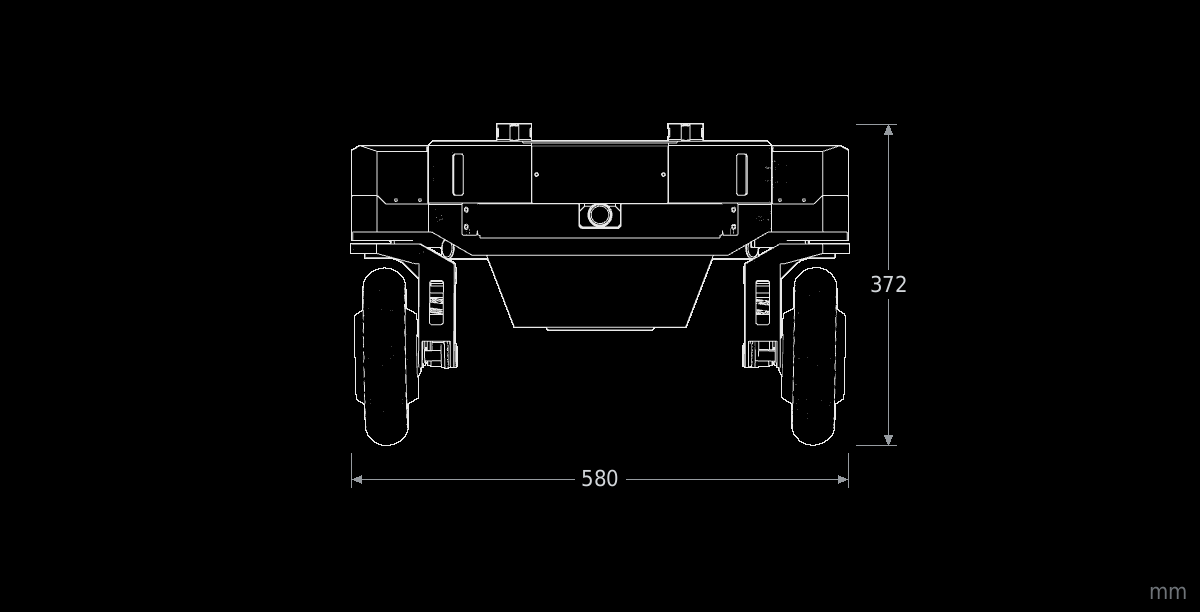
Currently displaying: Luchs A
Configuration Packages
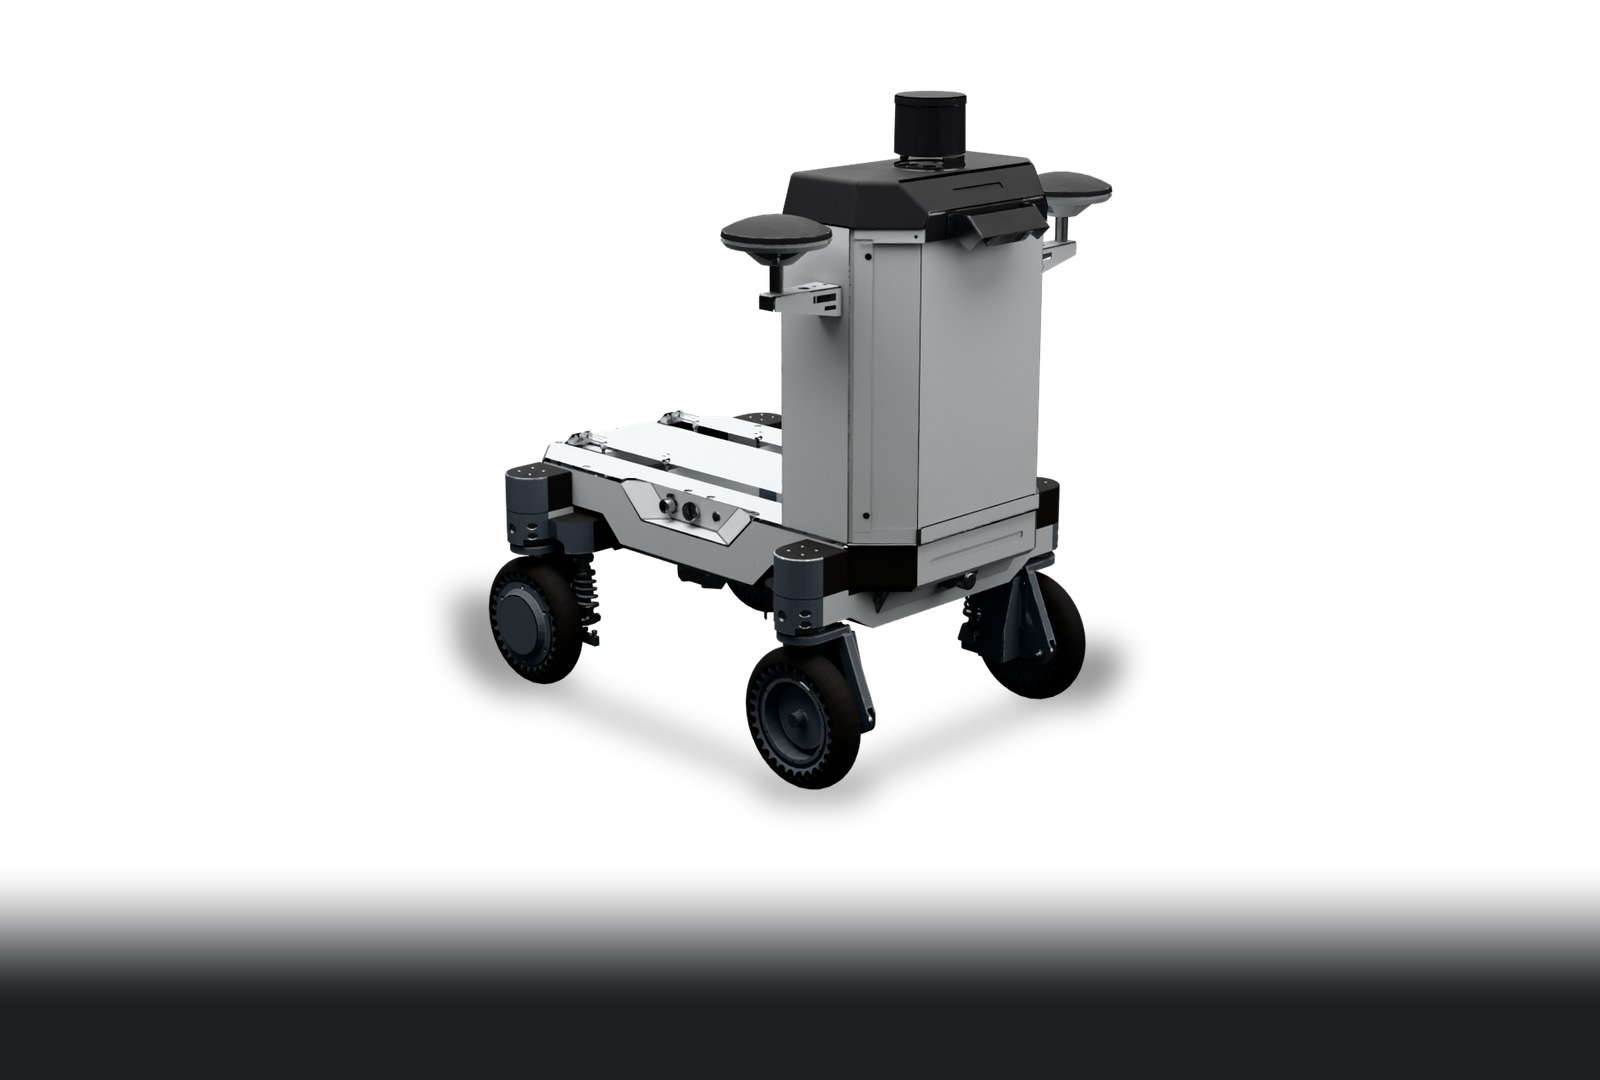
The preconfigured sensor packages offer everything needed to get started quickly. Additional hardware can be added or substituted upon request. Prefer to integrate your own sensors? Luchs A is also supplied as a bare chassis, with the published CAN protocol, SDK and simulator.
Full Autonomous Package
Sensor & Perception
Communication & Control
Indoor Navigation
Drive it around once to build a 3D LiDAR map, then pick any point on the map as a goal. It re-plans around new obstacles.
City Streets
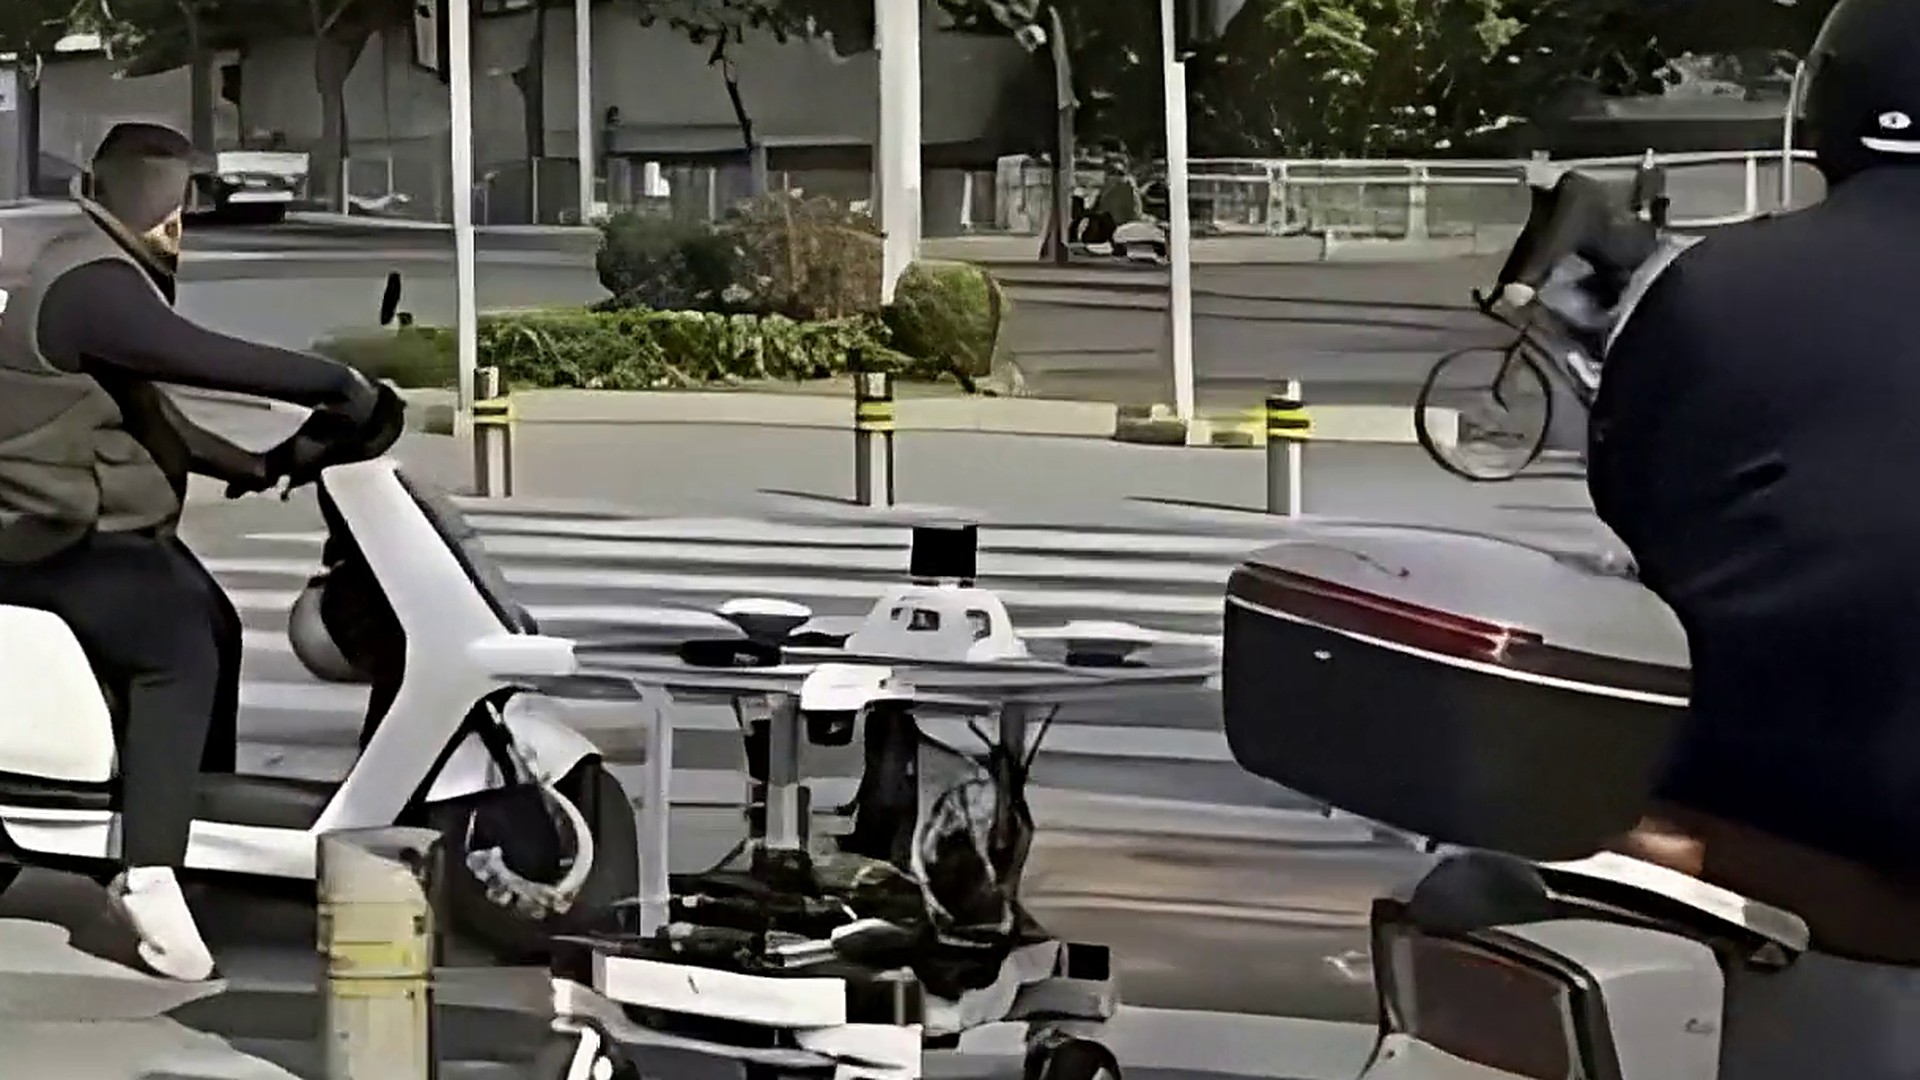
Gives way to people, passes bollards, waits for traffic and red lights, and crosses at zebra crossings.
Campuses and Plazas
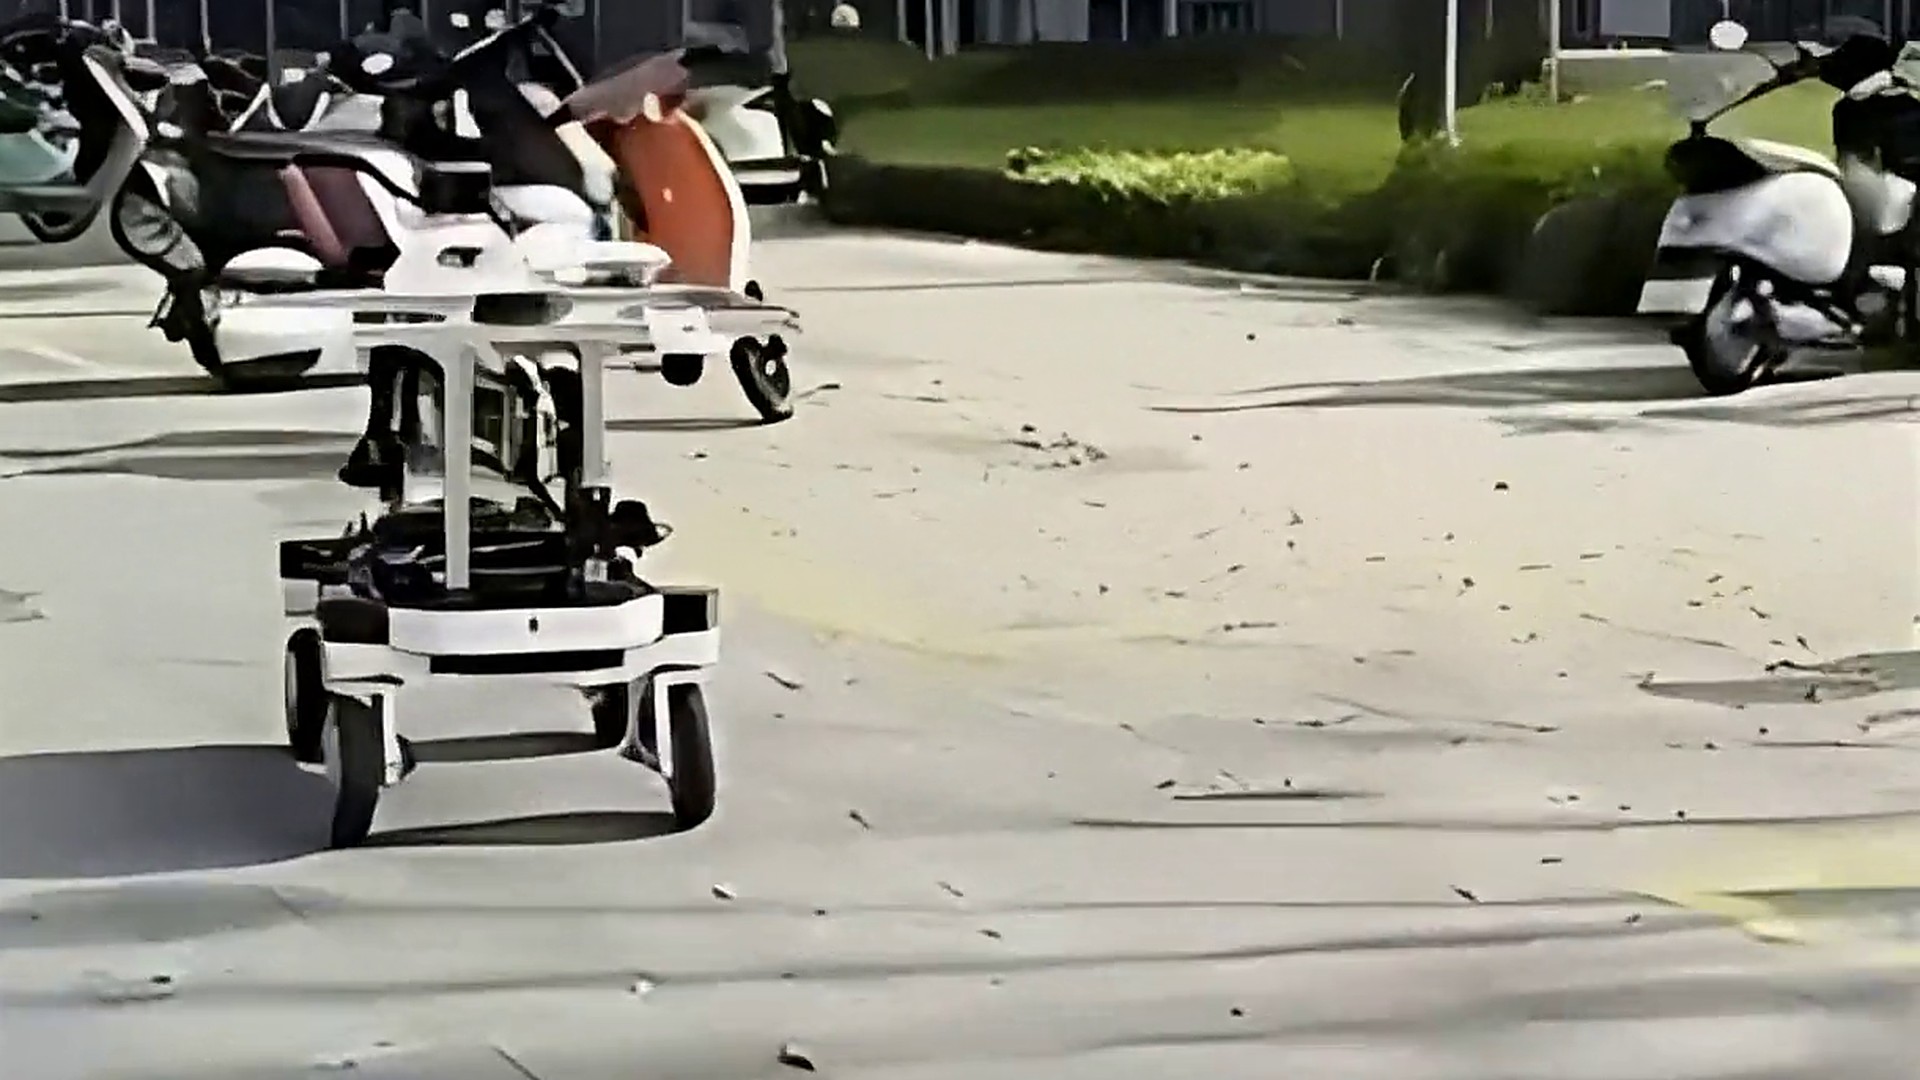
RTK GNSS keeps the position accurate on open ground. It drives to its goal and parks among the scooters.
Have a unique application? Let's discuss your custom requirements.
Gallery
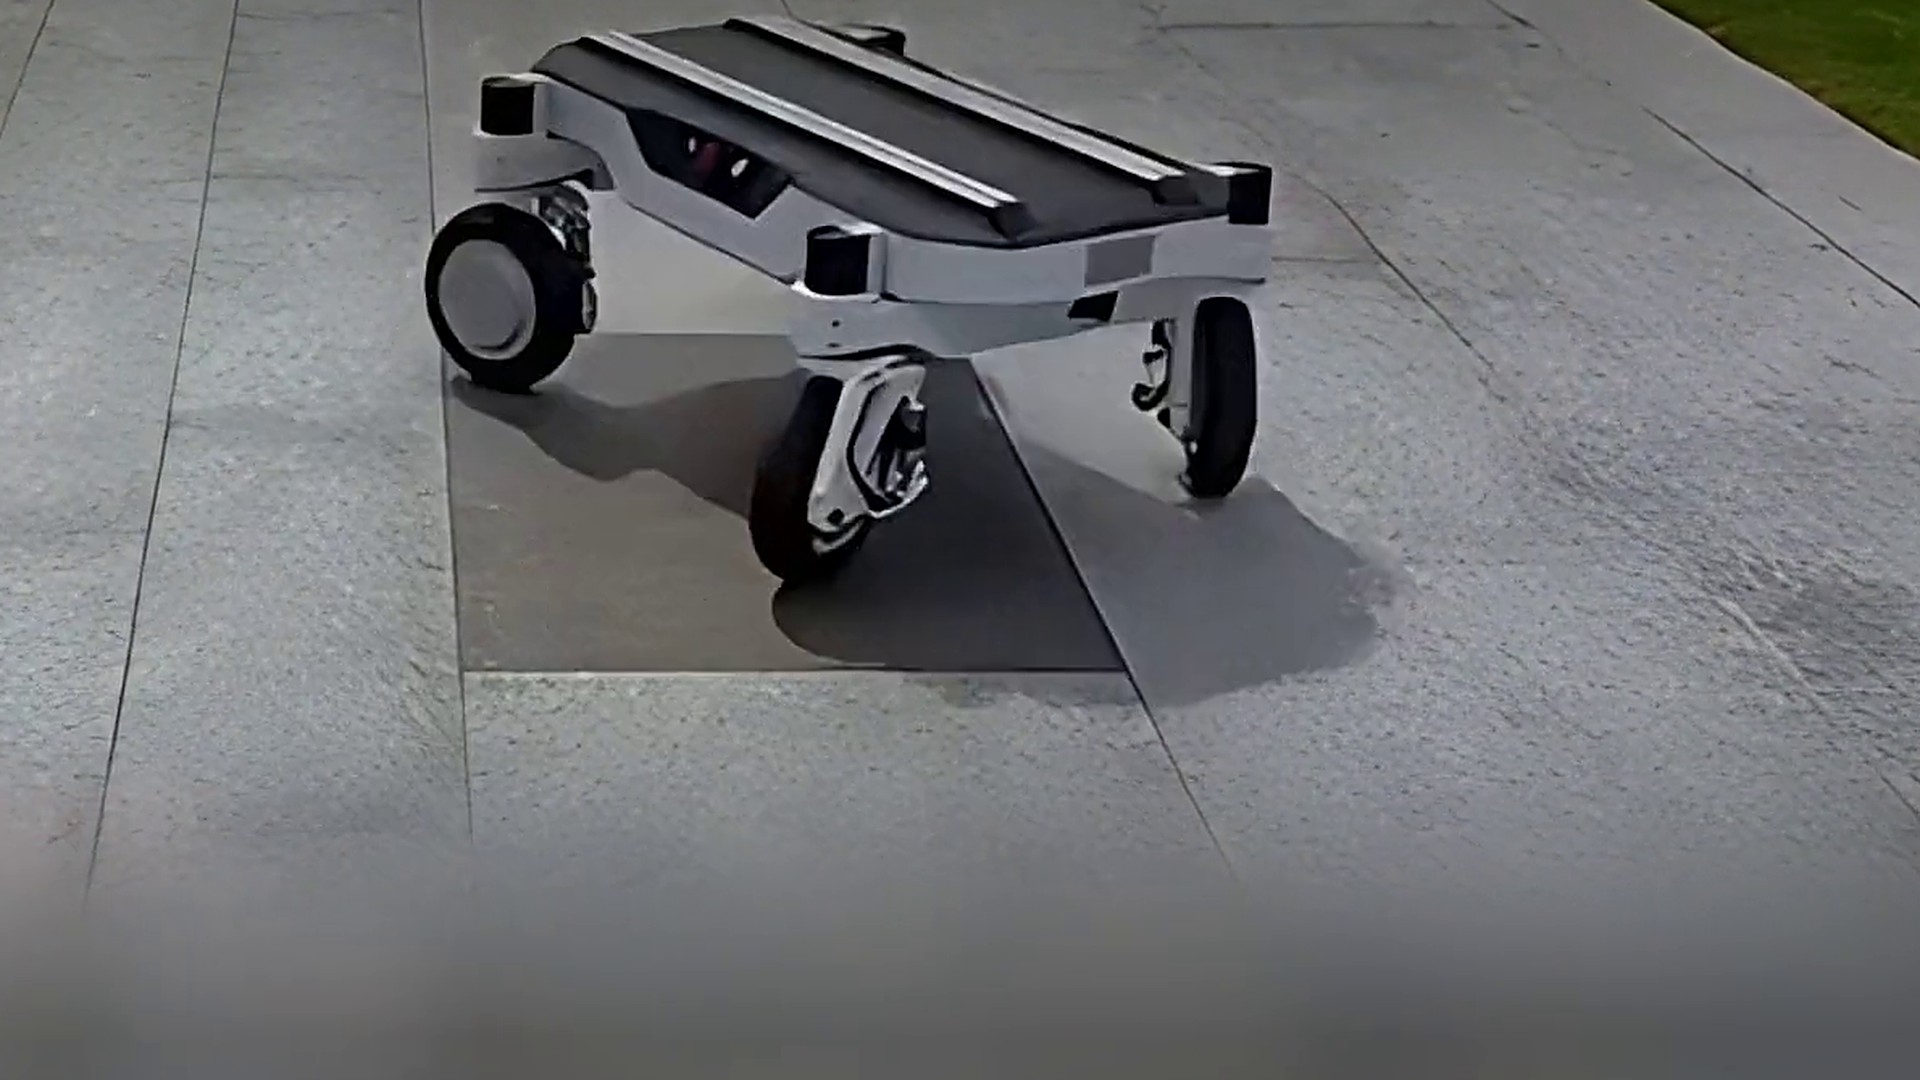
Luchs A at work: stills from our test and product videos. Pivoting on the spot and slipping through scooter traffic is where four-wheel steering earns its place. Available as a bare chassis or with the TAR navigation kit.
Media
Fixed-axle bases need room to turn; Luchs A does not. All four wheels steer: it crabs sideways, pivots on the spot and carries your payload, with CAN, RS-485, RS-232 and 48 V / 12 V power ready. Available as an open chassis, or with TAR autonomy on board.
Request a Custom Quote
Our team will work with you to configure the perfect chassis for your autonomous vehicle application.
-
Features
-
Tech Spec
-
Packages
-
Gallery
-
Media
-
Documents
Access Technical Documents
· Technical White Paper – In-depth analysis of vehicle engineering and reliability
· Test Reports – Detailed performance and endurance test data
· Battery Specifications – Certified battery specs and compliance details
Please complete the form to the right, and our technical team will deliver the requested documents directly to your inbox.
DOWNLOAD NOW
-
First Name*
-
Last Name*
-
Email*
-
Name of Organization*
-
Country*
-
State/Prov*
-
Information Requested*
-
Please register for email subscriptions about RJTech and the latest developments (you can unsubscribe at any time).YesNoClick here for our privacy policy.